DATA OPERATIONS FOR PHYSICAL AI

Field data your robot can learn from.

Rodayta helps robotics teams turn real environments into structured training data. We plan capture, coordinate operators, annotate task events and validate deliveries against your specification.

Egocentric and multi-viewTask-aligned annotationAcceptance-led QA
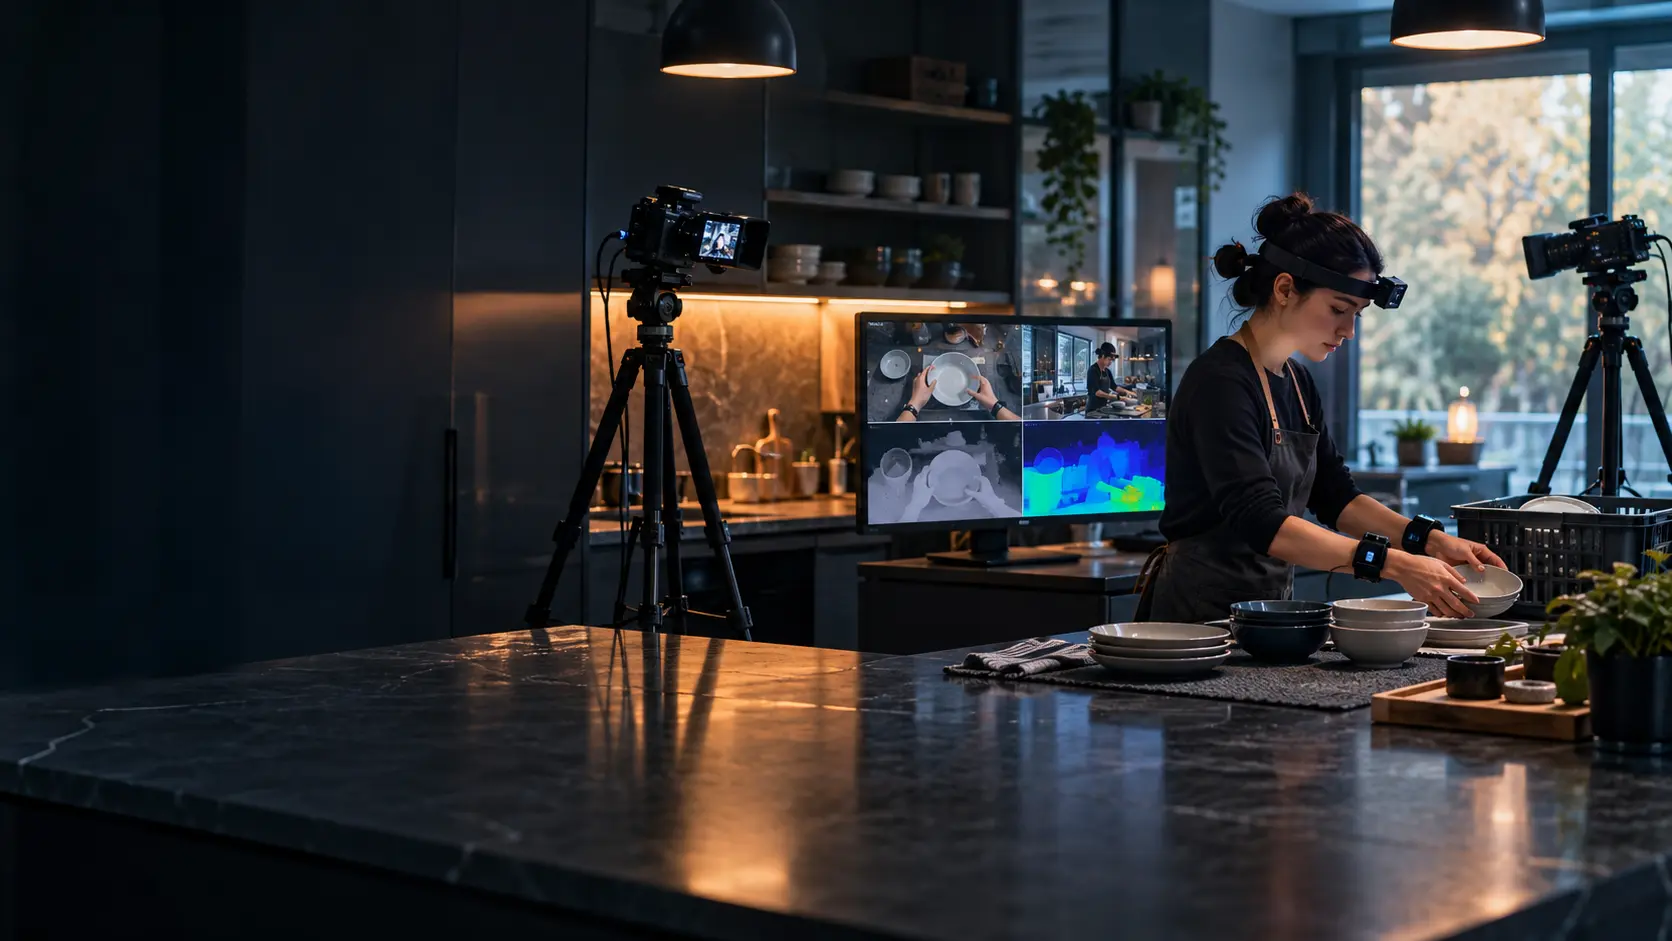
Illustrative multi-camera data capture setup in a kitchen
01 / FIELD CAPTUREIllustrative visual

BUILT AROUND YOUR SPEC

Real-world collection is useful when the result can be inspected, accepted and trained on.

From camera placement to task taxonomy, every decision is connected to the model objective and the data contract. Start small, review representative sessions, then scale the workflow that passes.

01 / CAPABILITIES

One operating partner across the data lifecycle.

Engage us for a focused workstream or an end-to-end program. The sensor stack, annotation schema and acceptance rules are agreed during scoping.

01

Real-world capture

Task design and field execution for household, object-handling, packing and selected assembly workflows. We coordinate locations, operators, camera placement, SOPs and session logging.

  • Monocular or stereo egocentric video
  • Ego, exo and wrist views where scoped
  • Task instructions and capture metadata
Explore workflows
03

Quality and delivery

Automated checks and human review catch technical and task-level failures before handoff. Issue logs, recapture decisions and accepted-session manifests keep each batch traceable.

  • Completeness, timing and view checks
  • Batch-level exception tracking
  • Customer-defined output schema
Review our QA flow

02 / FIELD WORKFLOWS

Capture designed for the task, not a generic footage quota.

We work from a task list and an explicit definition of a usable session. These are representative program directions. Final feasibility depends on the site, devices and acceptance criteria.

01 / HOME

Domestic manipulation

Kitchen routines, cleaning, sorting and object transfers captured as complete, observable task sequences.

EgocentricMulti-viewTask outcome
02 / OPERATIONS

Packing and logistics

Pick, inspect, pack and reset workflows with natural variation in items, positions and operator execution.

First personSubtasksExceptions
03 / PILOT SCOPE

Tool use and assembly

Feasibility-led pilots for repair, light assembly and tool handling, with safety and visibility requirements scoped first.

Pilot validationObject stateQA

03 / ANNOTATION

Labels that preserve the logic of the task.

A useful annotation workflow begins with clear definitions. We align the schema to your training objective, then review ambiguous events together before bulk labeling.

EXAMPLE SESSION VIEWILLUSTRATIVE
EGO VIEW00:18:42
00:0000:1500:3000:45
TASK
Clear table
ACTION
ReachGraspPlace
RESULT
Pass

Concept illustration. Annotation classes and review thresholds follow the agreed specification.

01

Temporal structure

Mark task boundaries, subtasks and meaningful action transitions with timestamped start and end points.

02

Objects and state

Describe manipulated objects, relevant state changes and the final condition needed to judge completion.

03

Outcome and failure

Separate completed attempts from partial or failed attempts. Record the cause when it is observable.

04

Review and escalation

Escalate ambiguous footage, sample reviewer agreement and retain corrections alongside the batch record.

04 / ACCEPTANCE-LED QA

Know why a session passes, fails or needs recapture.

Each pilot starts with a written acceptance matrix. The review process combines file-level checks with human judgment about task visibility and completion.

Share your acceptance criteria
01 / PREFLIGHT

Capture readiness

Device settings, camera coverage, calibration evidence, task instructions and operator briefing.

02 / TECHNICAL REVIEW

File and signal integrity

Duration, resolution, frame rate, timestamp continuity, missing channels and synchronization where required.

03 / HUMAN REVIEW

Task validity

Hand and object visibility, task progression, outcome, privacy issues and exception classification.

04 / DECISION

Accept, correct or recapture

Every decision is tied to a reason code so the next batch can improve.

05 / WHAT YOU RECEIVE

A delivery you can inspect before it enters the training pipeline.

The exact file structure is agreed in the pilot. This example shows how source media, annotations and QA evidence can travel together.

RODAYTA / SAMPLE DELIVERYILLUSTRATIVE

▾ accepted_batch/

▾ session_001/

◧ ego_video.mp4

◧ exo_video.mp4 if scoped

▤ timestamps.csv

▤ annotations.json

▤ accepted_sessions.csv

▤ issue_log.csv

▤ qa_summary.pdf

▤ schema_and_readme.md

Designed for handoff.

We can organize the final batch around your session IDs, task taxonomy, media channels and metadata requirements. Format mapping and any training-framework conversion are scoped and tested on a golden sample.

  • Raw and accepted-session indexes
  • Label definitions and versioned schema
  • Exception and recapture log
  • Batch QA summary and review notes

Final modalities, formats and rights are defined in the statement of work.

06 / ENGAGEMENT MODEL

Start with a pilot. Scale what works.

A small paid validation phase exposes camera, workflow and annotation issues early. Scope and commercial terms are agreed before collection begins.

  1. 01

    Share the brief

    Tell us the robot task, environments, sensors, target volume, output schema and acceptance rules.

  2. 02

    Design the pilot

    Agree the capture setup, operator SOP, label taxonomy, review plan and delivery checklist.

  3. 03

    Review golden samples

    Inspect representative sessions together, correct ambiguity and freeze the working specification.

  4. 04

    Deliver by batch

    Track usable data, issues and recapture decisions against agreed milestones.

07 / LET'S TALK DATA

Tell us what your robot needs to learn.

Send a task specification or a short brief. We will use it to prepare a feasibility conversation and outline the information needed for a pilot.

DIRECT CONTACT992scofield@gmail.com
OFFICE LOCATIONHong Kong SARCity-level location. Full address to be confirmed.

Request a pilot discussion

Fields marked * are required

This form opens your email app. Your details are not stored on this website.